
The simulation was perfect. The robot followed its route, spotted the wall and stopped right where it should. Then you loaded the same code onto the real machine and everything went slightly wrong. It pulls to the left. It brakes late. It twitches back and forth around a target it hit cleanly on screen.
The code hasn’t changed, so what has?
It is rarely one dramatic fault. More often it is four or five small differences, each harmless on its own and awkward together. That is good news, because small differences can be found and measured. Here is where they tend to hide.
What the Reality Gap Really Is
The mismatch between simulated and physical behaviour is called the reality gap, or sim-to-real gap. A simulation runs on assumptions: motors obey instantly, sensors tell the truth and the floor is flat and grippy.
A real robot gets none of that. It is software, electronics and mechanics working together, and every layer brings its own flaws.
That isn’t bad programming. It is just physics doing its job.
A good simulation doesn’t copy reality. It copies the parts of reality that change the outcome.
If you are in a later-year robotics, mechatronics, automation or computer engineering module, this is where the question changes from “does it move?” to “does my model deserve to be trusted?”
Where the Gap Shows Up First
Drift. On screen, both wheels get the same command and turn identically. On the bench, one motor runs a touch faster, a wheel sits a degree out of line, and the floor grips each side differently. The robot curves away from its line.
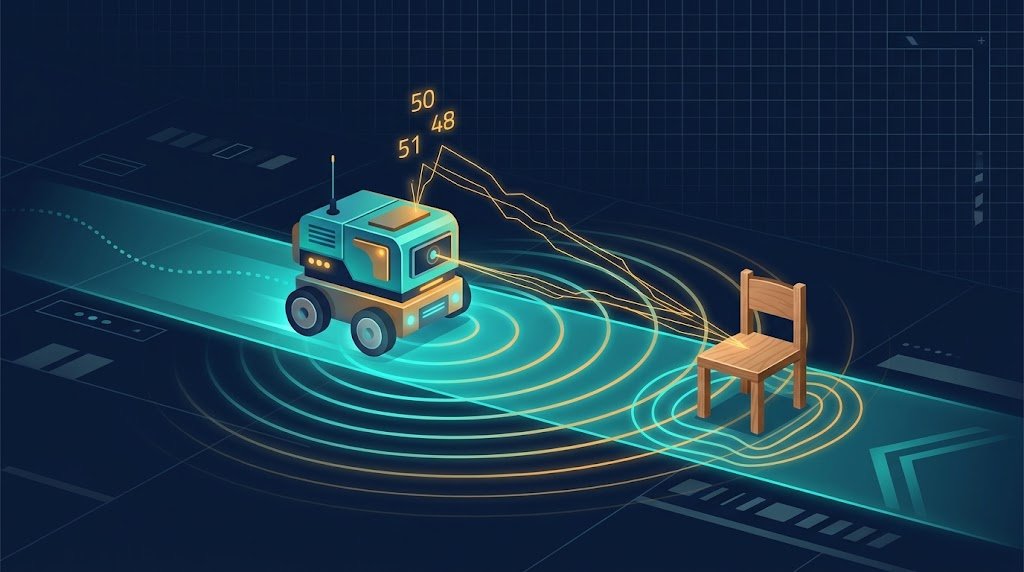
Noisy readings. An ultrasonic sensor bounces sound off an object and times the echo. A flat wall gives a clean return. An angled or soft surface gives a weak, patchy one. Same obstacle, different number each run.
Delay. In simulation, reaction looks instant. In reality the robot has to take a reading, process it and power the motors, and it keeps rolling the whole time.
The instinct at this stage is to rewrite the navigation code. Resist it. Check what the robot senses and what it physically does before you touch the algorithm.
Students looking for Robotics Coursework Help often assume a cleverer algorithm is the answer, when the marks usually go to whoever sets predicted and measured behaviour side by side and explains every difference.
The Concepts Behind Most of It
Sensor noise. Hold the robot still facing a wall and the sensor might say 48 cm, then 50, then 47. The wall has not moved. A controller that reacts to every reading will twitch constantly.
A moving average smooths that out, but there is a catch: more filtering means slower reactions. Filter too hard and a real obstacle gets noticed late.
Actuator limits. Motor output depends on torque, supply voltage, friction, load and inertia. An arm that lifts a test weight neatly in simulation may sag once a real payload changes the forces on each joint.
PID control. The proportional term reacts to present error, the integral to accumulated error and the derivative to how fast the error is changing. Gains tuned in a clean simulation often overshoot or oscillate once noise and delay arrive. Expect to retune on the hardware.
Domain randomisation. Rather than one perfect virtual world, vary friction, sensor noise and motor strength between runs so the controller never leans on ideal conditions. It improves transfer, though it never replaces a physical test.
Latency Is Really Distance
This is the check I would run first, because it takes two minutes. Delay converts straight into distance:
Distance covered during delay = speed × delay
A robot moving at 0.4 m/s with a 150 ms delay between sensing and motor response travels 6 cm before braking even begins. Told to stop at 30 cm, it ends up at 24 cm or closer, because braking adds more.
The sensor was fine. The code was fine. The delay did it.
Double the speed and the overshoot doubles. Time your control loop with a timestamp, do the sum, and many “mystery” errors disappear.
Make the Simulation Fail on Purpose
Before changing anything on the hardware, add three imperfections to the simulation: sensor noise matching the datasheet tolerance, a delay equal to your measured loop time and a 5% mismatch between the two motors.
If the virtual robot now fails the way the real one does, you have found your causes. If it still behaves perfectly, the model is missing something important.
I prefer this to guessing at gains because it turns hunches into evidence. Reproduce the failure in simulation first, then fix it.
A Bench Routine That Holds Up
Take one task: drive forward, detect a wall, stop at 30 cm. Run it in simulation, then on the robot, from the same start point.
- Record exactly what happens, with numbers rather than “it misbehaves”.
- Check sensor readings against a tape measure.
- Examine movement: do the wheels do what was commanded?
- Change one variable, then repeat.
- Run at least five trials to see whether an improvement is real.
Then try the turn test. Command a 90-degree turn at slow, medium and fast speeds and measure the real angle.
If the error grows with speed, suspect momentum, actuator limits or timing. If it stays constant, look at wheel alignment and calibration.
Mistakes Worth Avoiding
Trusting pretty graphics. Realistic visuals say nothing about friction or motor dynamics. A plain simulation with well-estimated parameters beats a glossy one built on guesses.
Confusing resolution with accuracy. Resolution is the smallest change a sensor can show. Accuracy is how close it is to the truth. A sensor can be beautifully precise and consistently wrong.
Changing several settings at once. Adjust gains, speed and calibration together and you will never know which one worked.
Believing one good run. A single success proves very little. Start position, floor and sensor behaviour all shift outcomes.
Over-detailing the model. Every extra parameter needs a sound estimate. Wrong friction values produce confident, misleading predictions.
The Bigger Picture
Think of the robot as a chain. Sensors decide what it believes. The controller decides what to do about it. Motors and mechanics decide what actually happens. The environment touches all three.
Simulation lets you test ideas cheaply. Physical testing tells you whether those ideas survive contact with the floor.
Treat the two as separate evidence: a model shows what happens under stated assumptions, an experiment shows what the machine really does. The best evaluations explain where they agree and where they do not.
Few things in engineering are as humbling, or as useful, as a robot that refuses to behave.
A robot that works in simulation has shown what its model allows. One that works reliably on the bench has shown its design can cope with imperfection.
 max.leo
 calculators.king